One Wheel Is Enough: Control Strategies for the 3+1 Actuator Architecture Across Small Satellite Mission Profiles
Accepted, 77th International Astronautical Congress
I build autonomous robotic and control systems at the intersection of mechatronics, software, and space technology. My goal is to engineer the machines and technologies that will help take humanity beyond Earth.
Python-based satellite ADCS for all
Flight-Ready Attitude Trajectory Planning
A Modular Open-Source Python Framework for Small Satellite Attitude Determination and Control
SmallSat Europe 2026
A Feasibility-Aware Attitude Trajectory Planner for Underactuated and Unconventionally Actuated Small Satellites
SmallSat US 2026
Generalized Attitude Control Allocation for Small Spacecraft
SmallSat US 2026
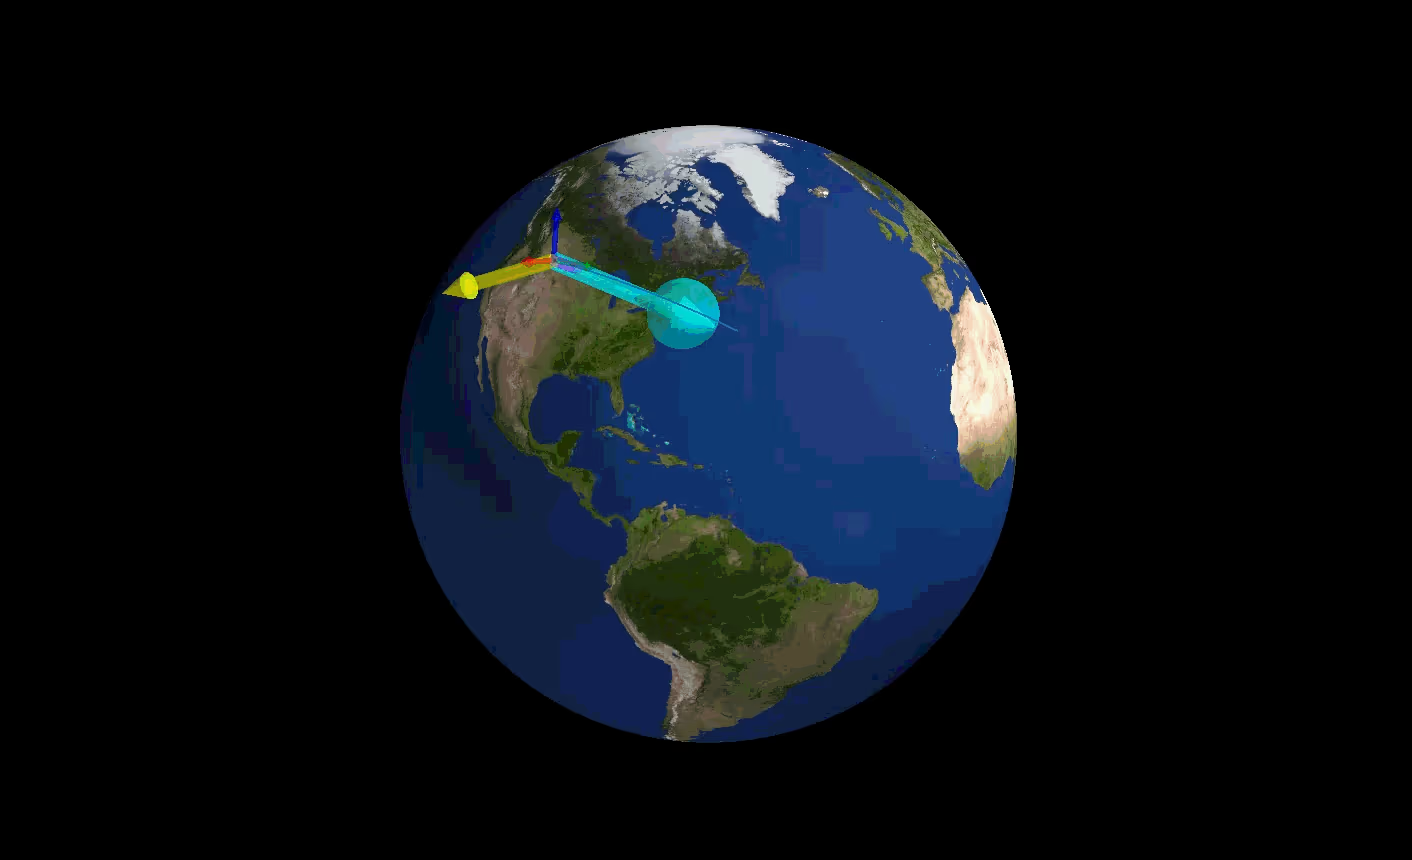
One Wheel Is Enough: Control Strategies for the 3+1 Actuator Architecture Across Small Satellite Mission Profiles
Accepted, 77th International Astronautical Congress