Generalized Attitude Determination and Control System
GitHub repository: nscheuer/Generalized_ADCS
A Python-first framework for simulating spacecraft attitude dynamics, estimation, and control in orbit.
Generalized ADCS is designed for aerospace students, researchers, and engineers who want a flexible, transparent ADCS simulation environment without black-box solvers.
Latest Release Notes
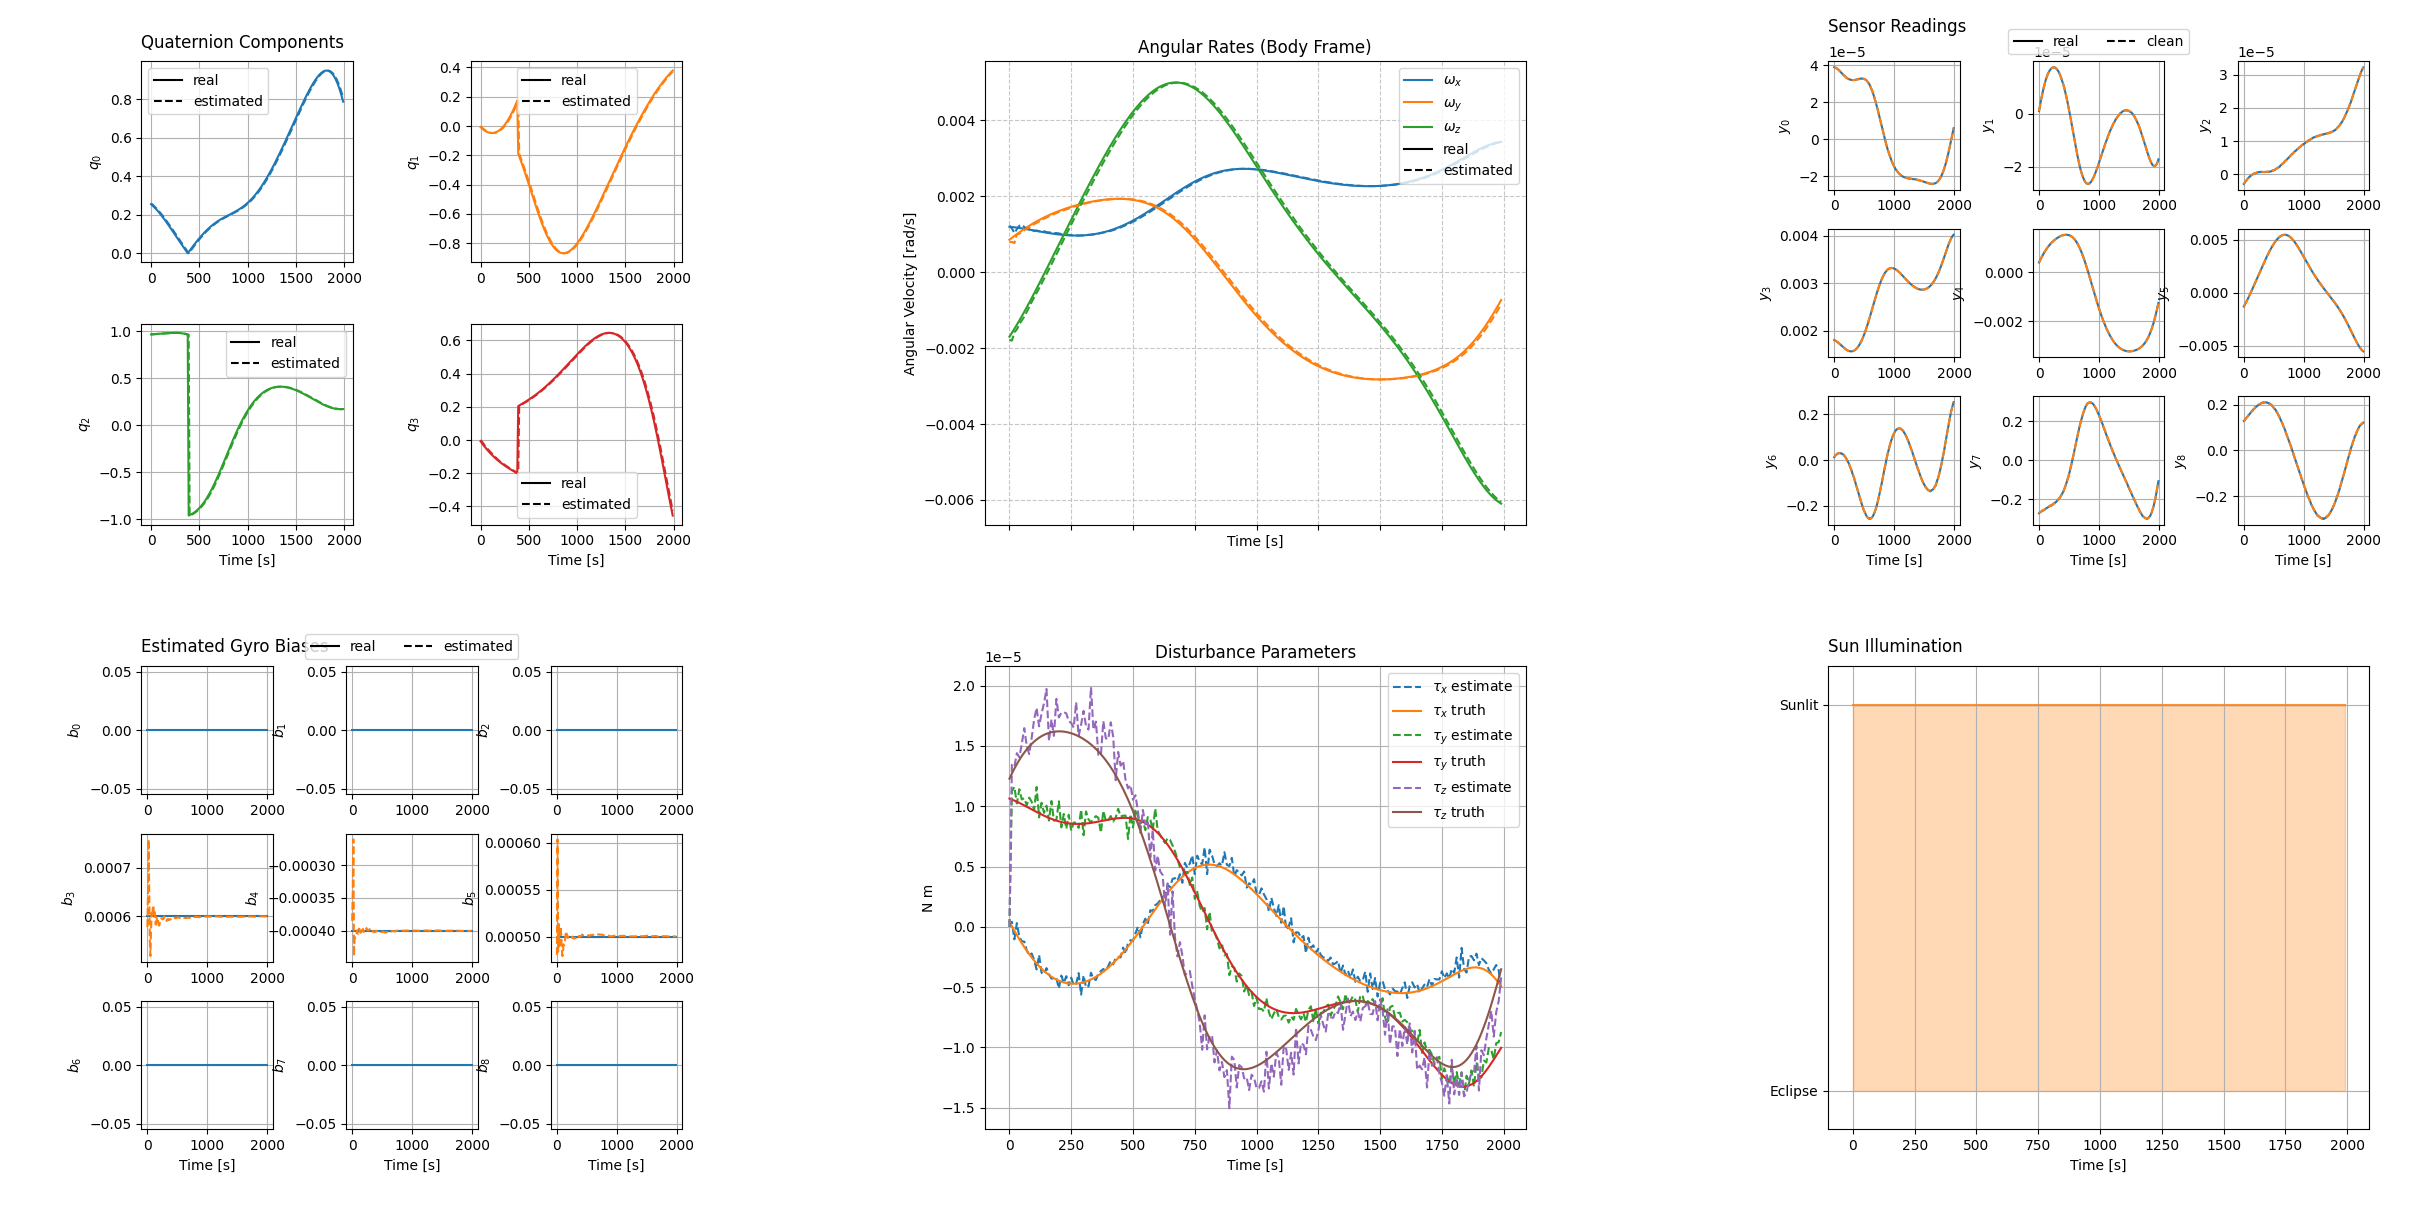
New Estimation Framework
Named state and covariance classes, a canonical measurement stack, shared process models and noise, a new attitude-estimator base, and eight new attitude estimators.
Explore release note 2.0
Generalized ACS Pipeline
Use smart actuator selection, torque compensation, control law transformation and goal selection to maximize the performance of your control law.
Explore update 0.1.8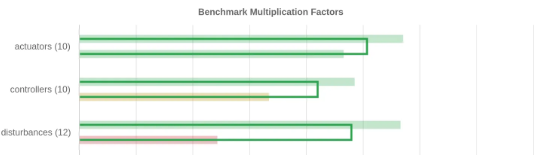
Benchmark
New performance benchmarks run on every pull request into main and compare results to catch regressions early.
What you can do with Generalized ADCS
Simulate rigid-body spacecraft attitude dynamics
Combine reaction wheels, magnetorquers, and sensors
Implement and test custom controllers and estimators
Run closed-loop simulations using orbital states
Visualize pointing performance and control effort
Spacecraft states use ADCS.State, with named w, q, and h
arrays. Estimator inputs and outputs use ADCS.EstimatorState, which
adds named bias and disturbance parameters plus covariance matrices. Use
from_array and as_array only at numerical-library boundaries; state
objects intentionally do not support NumPy indexing or implicit conversion.
import ADCS as ADCS
import numpy as np
import matplotlib.pyplot as plt

acts = [ADCS.RW(axis=np.array([1, 0, 0]), max_torque=0.0023, J=5.7e-6, h=0.0, h_max=0.0036)]
acts += [ADCS.MTQ(axis, max_torque=0.2) for axis in np.eye(3)]
sens = [ADCS.MTM(axis) for axis in np.eye(3)]

satellite = ADCS.Satellite(mass=10, J_0=np.diag([0.03, 0.03, 0.01]), actuators=acts, sensors=sens, boresight=np.array([0, 0, 1]))
x_0 = ADCS.State.from_array(np.array([0.01, -0.02, 0.01] + [1, 0, 0, 0] + [0.0]))  # w, q, h

controller = ADCS.controller.MTQ_w_RW_LP(est_sat=satellite, p_gain=0.00005, d_gain=0.002, c_gain=0.001, h_target=np.array([0, 0, 0]))

goal = ADCS.goals.Coordinate_Goal(lat=42.36, lon=-71.06, alt=0)
os0 = ADCS.Orbital_State(ephem=ADCS.Ephemeris(),J2000=0.22, R=np.array([5000, 0, 5000]), V=np.array([0, 7.5, 0]))

results = ADCS.simulate(
   x=x_0,
   satellite=satellite,
   controller=controller,
   goal=goal,
   os0=os0,
   dt=1.0,
   tf=500.0
)

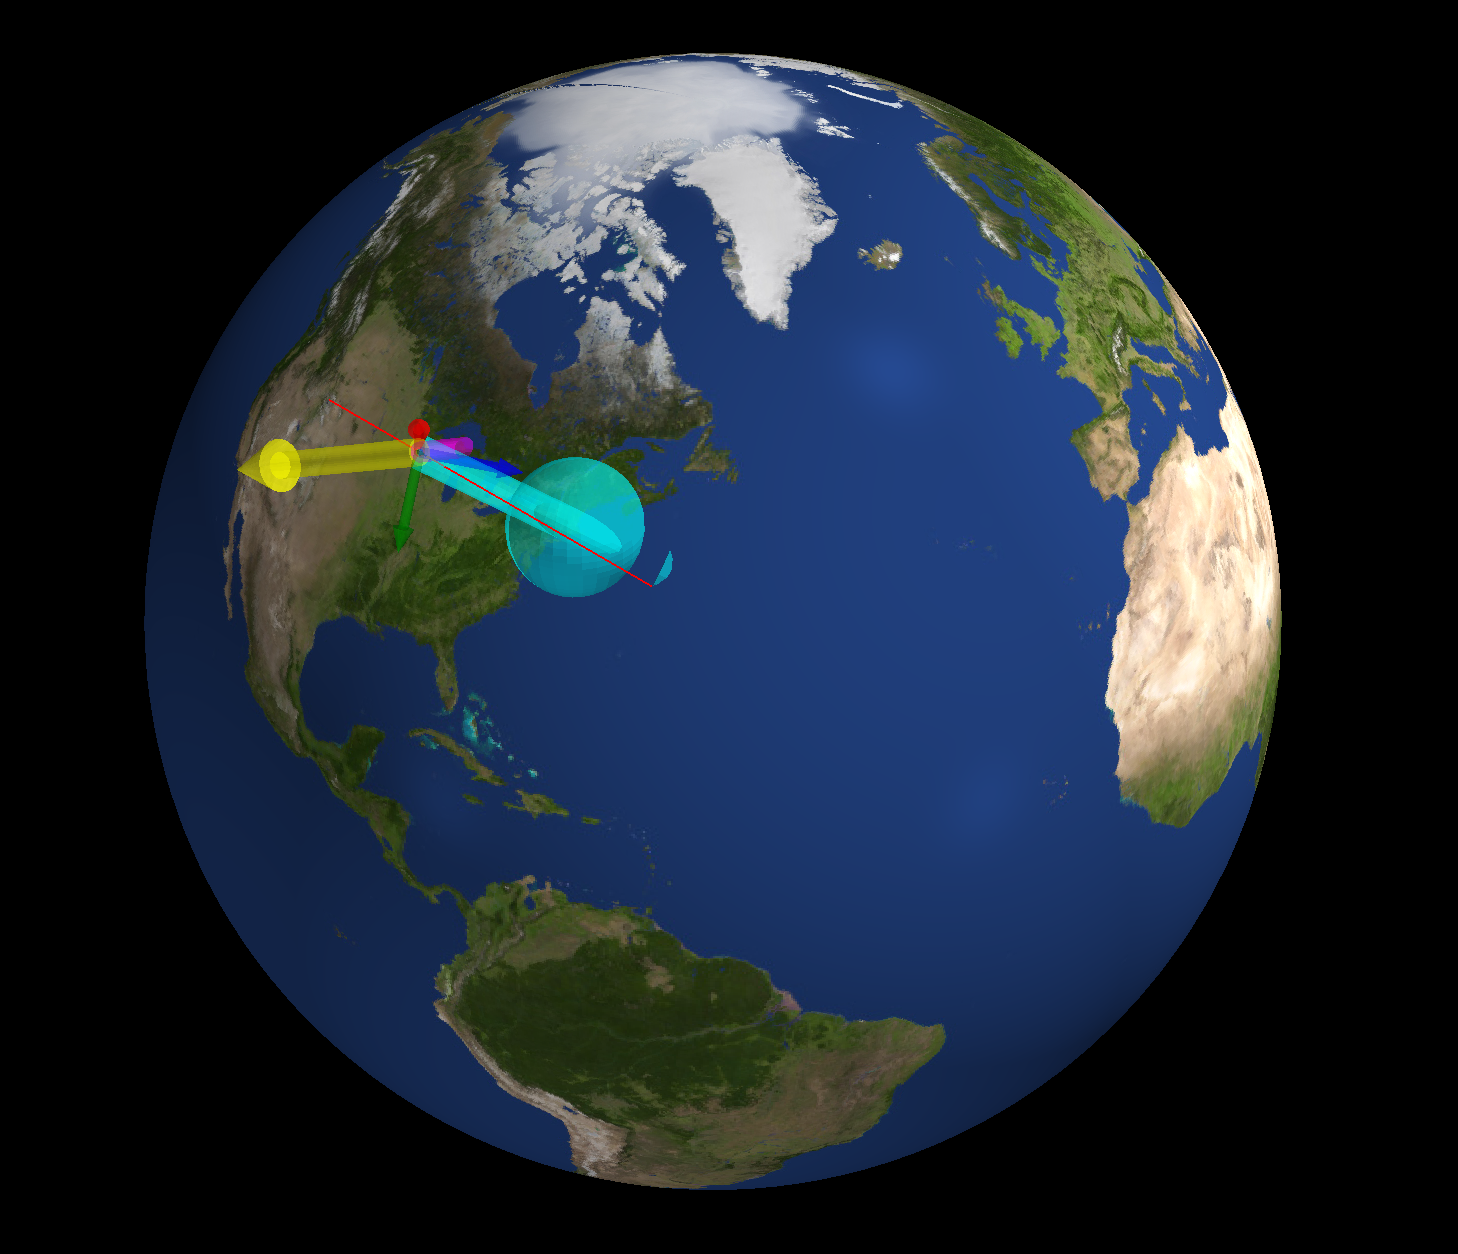
ADCS.plot(
   results,
   ADCS.plots.AnimationPlot(goal=goal),
   layout=(1,1),
   title="Underactuated Control Animation",
)

plt.show()
Getting Started
Function Documentation
Contributing